Work / Fig 03 · 2026
Fully Autonomous Soccer Rover
A fully autonomous soccer rover for the TTU ECE Robotics Project Lab’s Raider Red Soccer competition. All decision-making on a single Pico 2 with 520 KB of RAM. No external communication.
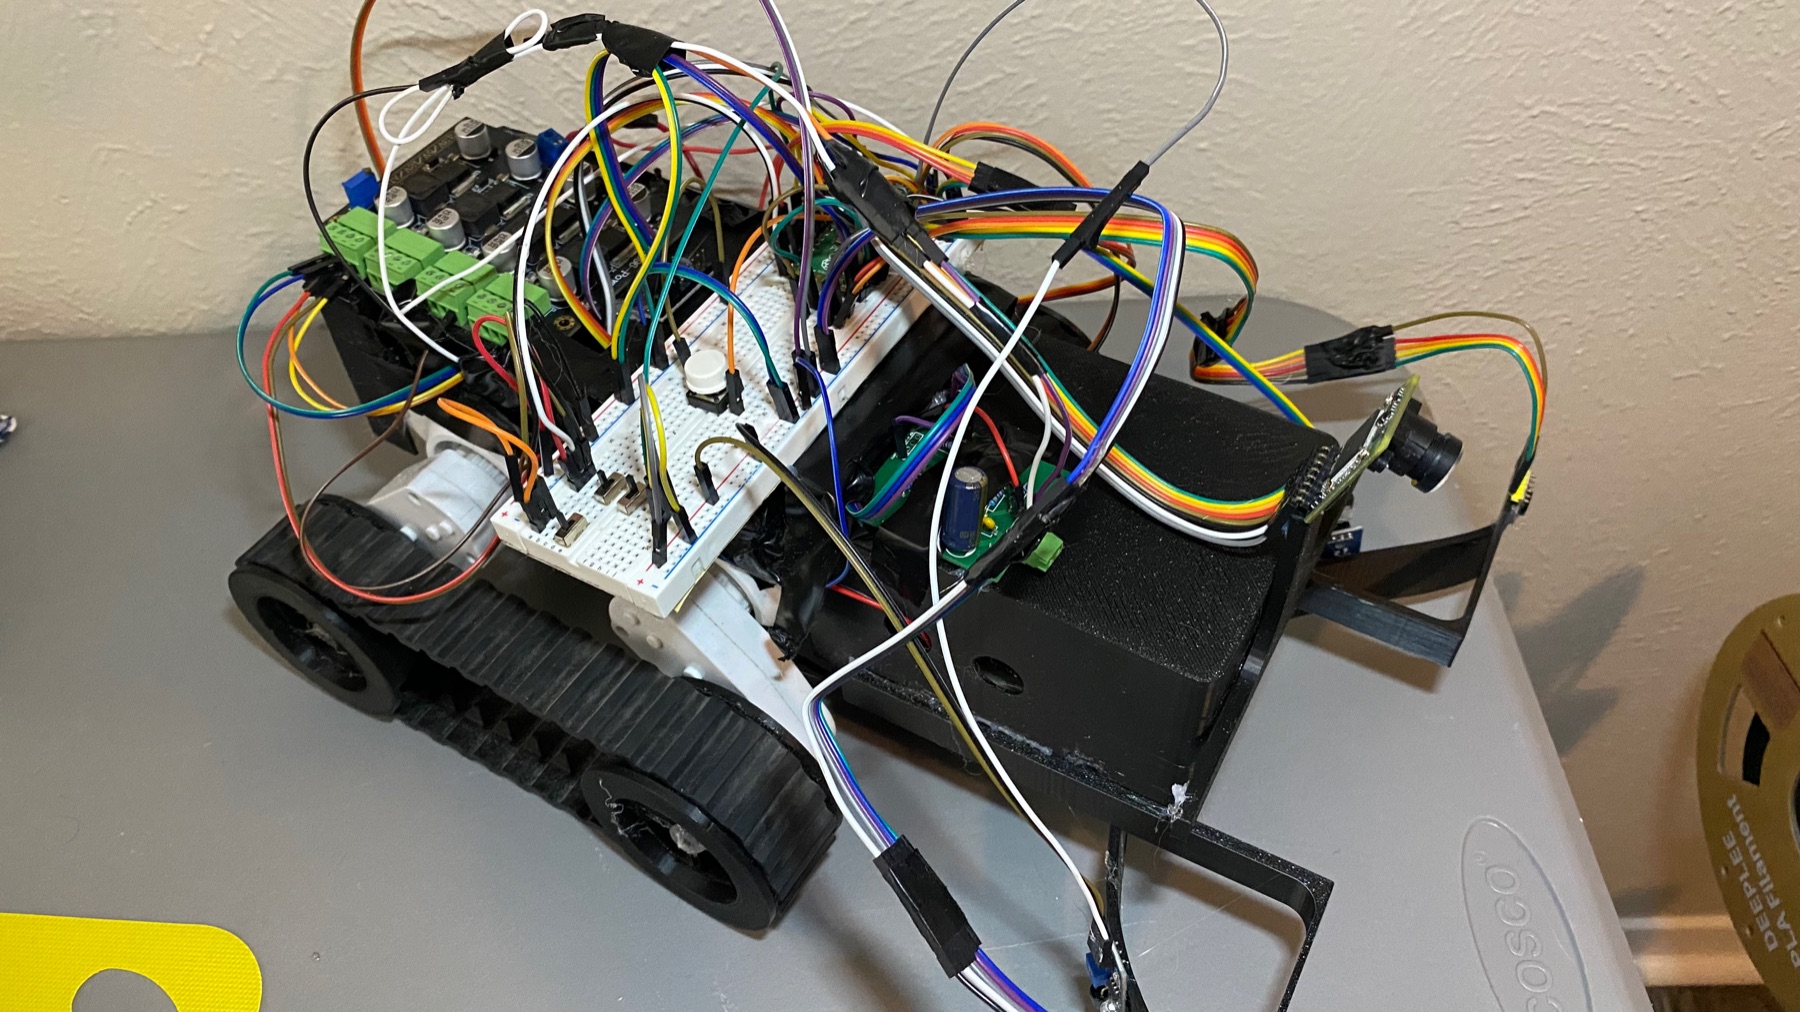
A tracked soccer rover with a Pico 2 on its custom board, a camera on a short mast and two ToF sensors at the front: a ball rolls back off the field wall into its intake, the servo gate drops behind it, the rover nudges forward, flips the gate up and kicks the ball back.
Embedded vision, sensor fusion, and real-time control
The machine
Built in Spring 2026 for the Texas Tech ECE Robotics Project Lab (ECE 3331) by a three-person team, Control Alt Defeat: Atharva Undire, Sam Graeber and Sergio Dominguez. The rover detects and classifies colored balls, estimates ball position from an onboard camera, avoids obstacles with dual ToF LiDAR, tracks field boundaries with IR sensors, and holds heading with IMU correction tuned to ~0.15°.
The work spans software, hardware and mechanical design, and Atharva designed and integrated the full system: camera calibration and filtering, ball centroid and size detection, color-based scoring logic, drivetrain control, servo gate actuation, ball intake and shooting, obstacle avoidance, field-position estimation, mechanical CAD, 3D printing, assembly, and iterative testing.
Constraints that mattered
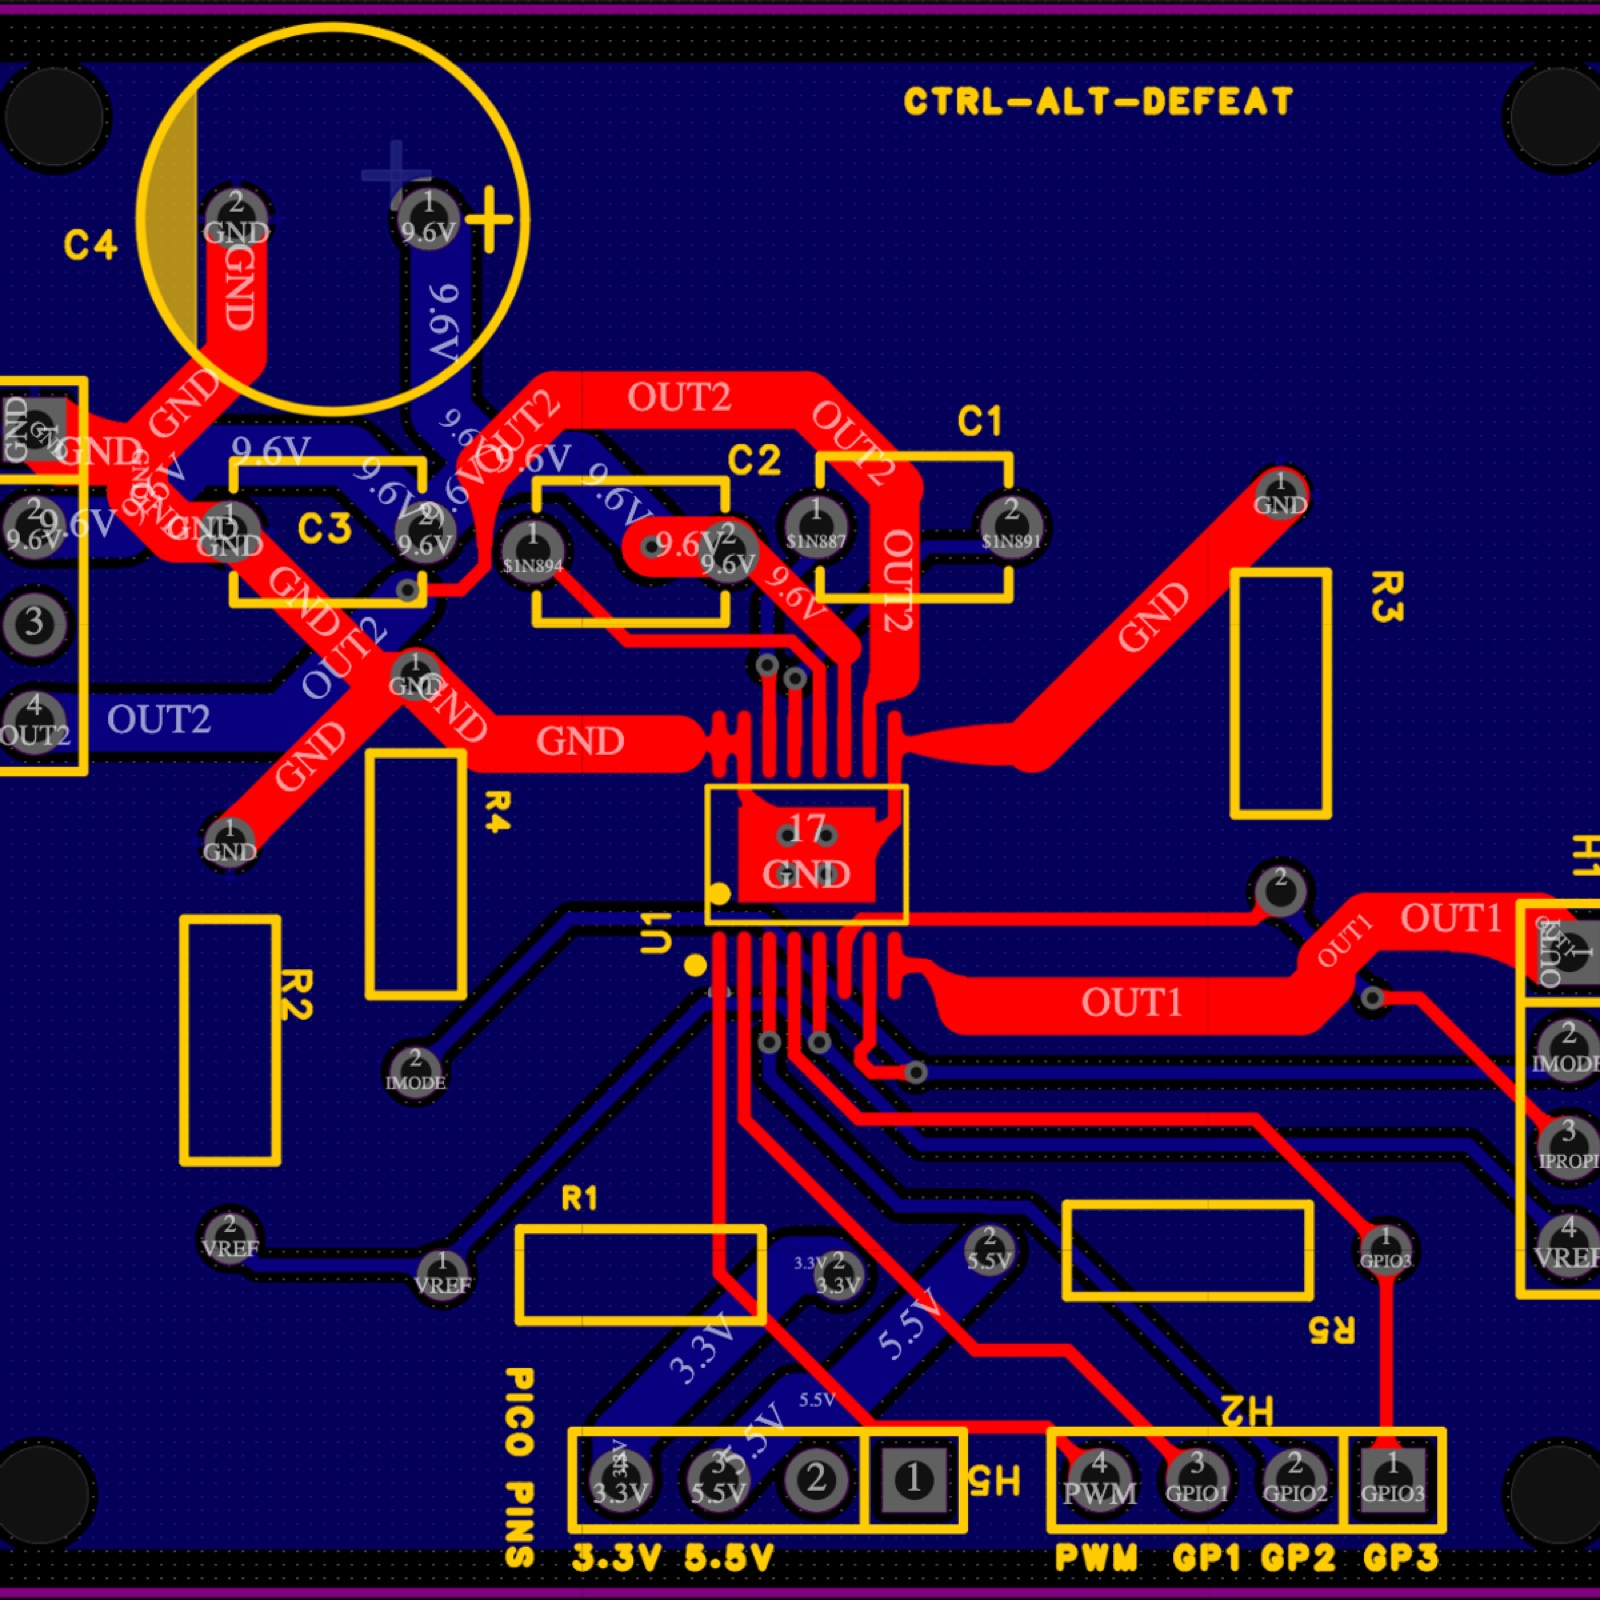
A custom PCB with DRV8876 motor drivers and overcurrent protection. Powered from a single 9.6 V NiMH pack under competition rules. No radios. All autonomy on a Pico 2 with 520 KB of RAM.
This is the work to keep doing: autonomous systems, robotics, embedded software, sensor fusion, controls, custom hardware, and full-stack hardware/software integration.
Stack
Links
Demo
YouTube ↗From the bench
2 images